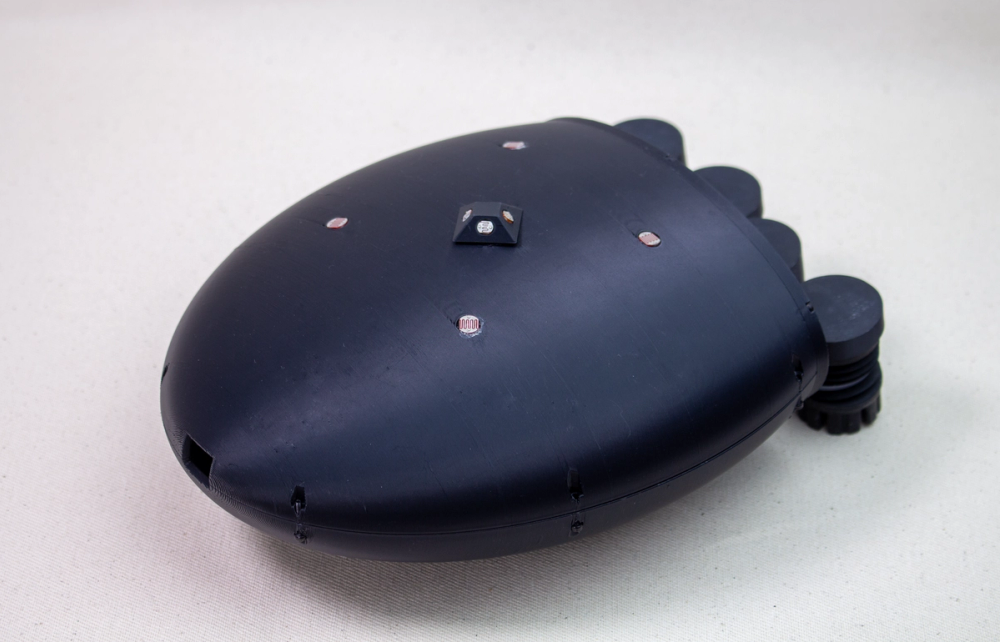
AWORM
Behind the scenes of AWORM, a self centered robot
How AWORM Works
AWORM function under a simple movement model, it goes forward, if it hits a cliff (Edge of the platform), it stops and sometimes evaluates itself to see if a recalibration is neccessary.
Test
What do AWORMs Do?
AWORM is determined to keep its sensors calibrated and it has a suite of actions under its toolbelt to do so. It can:
- Go Forward
- Turn
- Go Backwards
- Stop
- Sense Cliffs
- Evaluate Sensors
- Calibrate Sensors
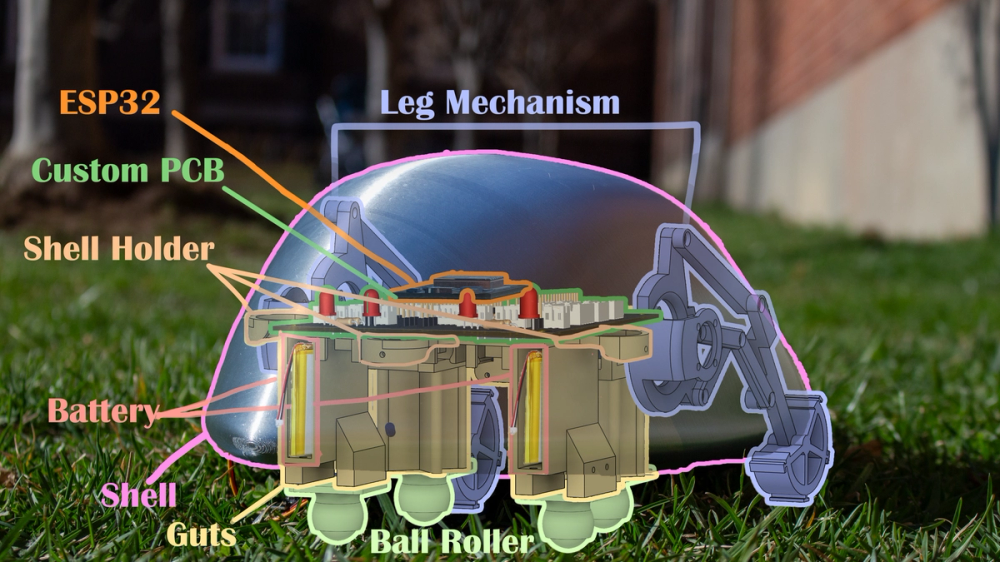
With this set of movements, AWORM is able to naviage a 8 ft by 8 ft platform without falling and keep its onboard acceleronmeter calibrated during DFX.
The general flow of movement looks something like this:
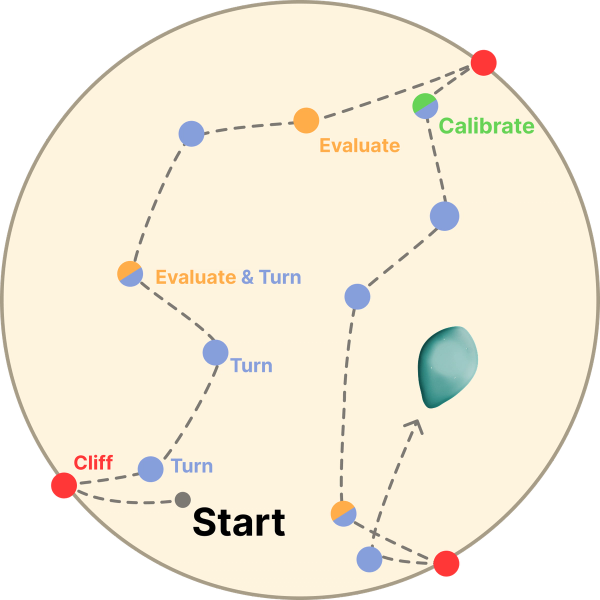
It will try to keep itself from falling, while stay as close as possible to the edges where is most "habitable". In which, it can conduct self-calibration undisturbed.
Context
AWORM works within a few different contextual backgrounds. It is a piece of very simple Hardware Artificial Life, under the embodied robot category, it is also in the discourse of HCI where it offers an alternative way for HCI where people needs to tap into AWORM's sensors instead of have AWORM's sensor built round people's input.
AWORM's Goal
AWORM’s goal
is developed through an iterative process where it went through 2 major iteration and dozens of miner modifications with the human designer. The development process shifts the conventional designer and designed-object hierarchy to a collaborative journey between them, creating a shared experience and agency between robot and human.
With the use of a specialize Iterative Loop, and by having an opaque shell on AWORM, the designer is forced to observe and to make assumptions instead of having direct access to its internal states when AWORM is being tested and developed.
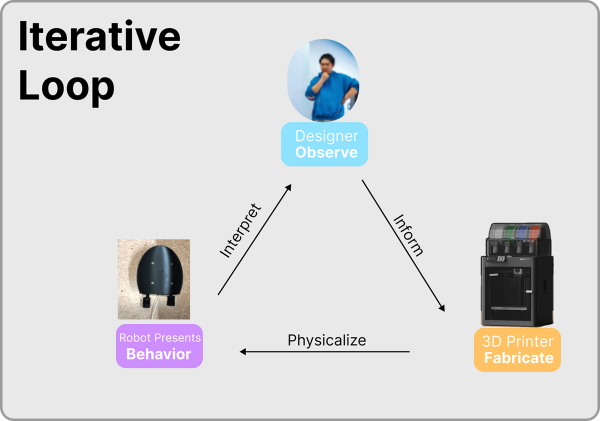
This grants AWORM agency in its own development process, it can shape its own development process by presenting different behaviors, where those behaviors will be interpreted by the designer and making improvements based on observations, rather than being shaped solely by the designer's intentionality.
Iterative Map
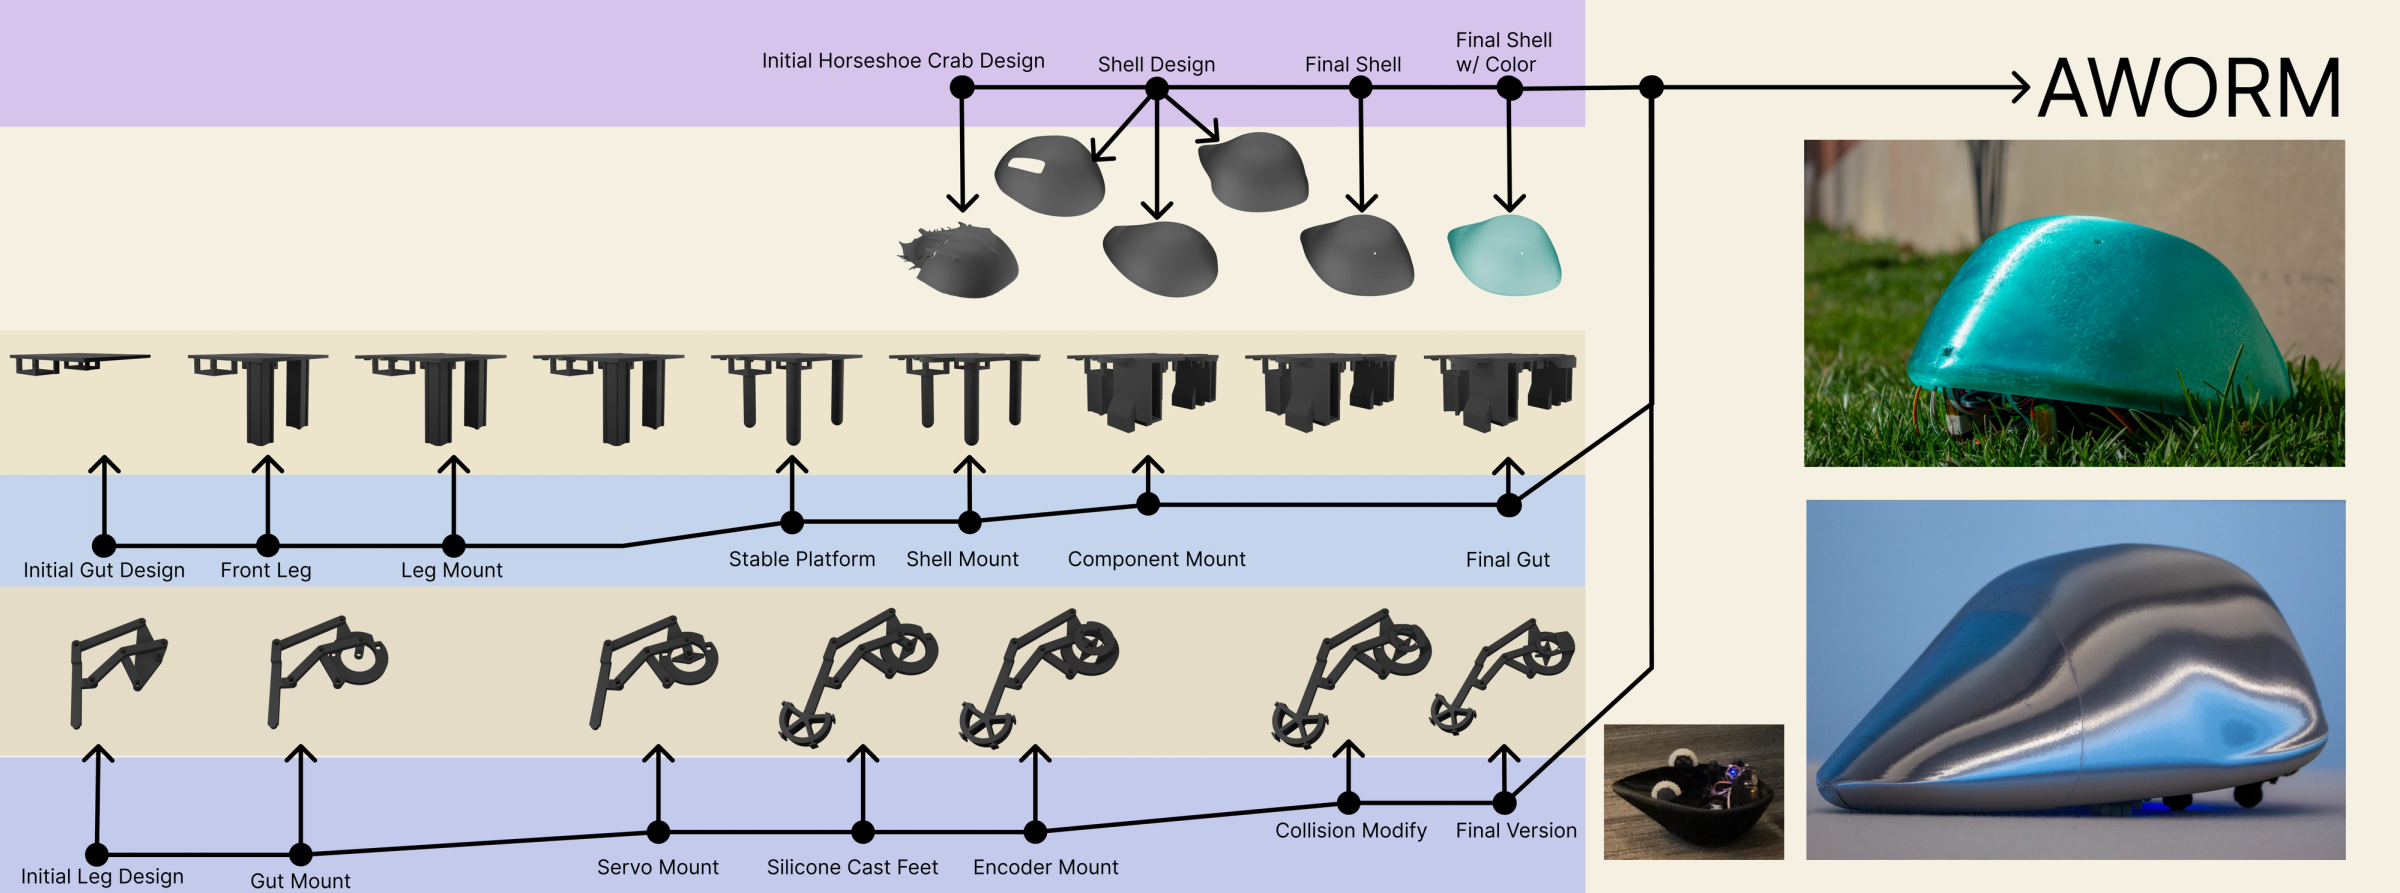
Each iteration is a "conversation" done between the robot and the designer, each have their own concerns, and by collaborating on AWORM, their concerns materialized into phyiscal world with 3D printing tehcnology.
Previous Iteration
AWORM started with something more wobbly. It started as a spherical creature that wobbles around rather than walks around.